The Loop Earns Trust
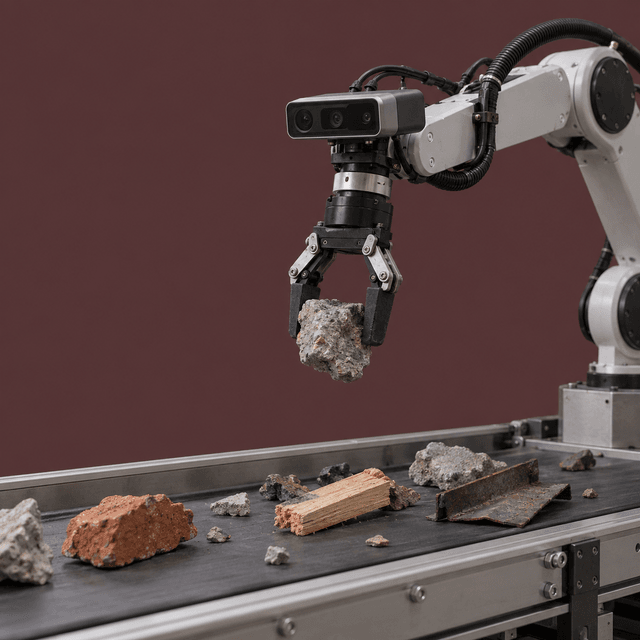
A sorting robot filters unreliable detections before it moves, a soft device remembers touch, and a battery failure becomes visible in fluorescence. Across materials, machines, displays, and mobility, the harder design problem is making state legible enough to support the next action.
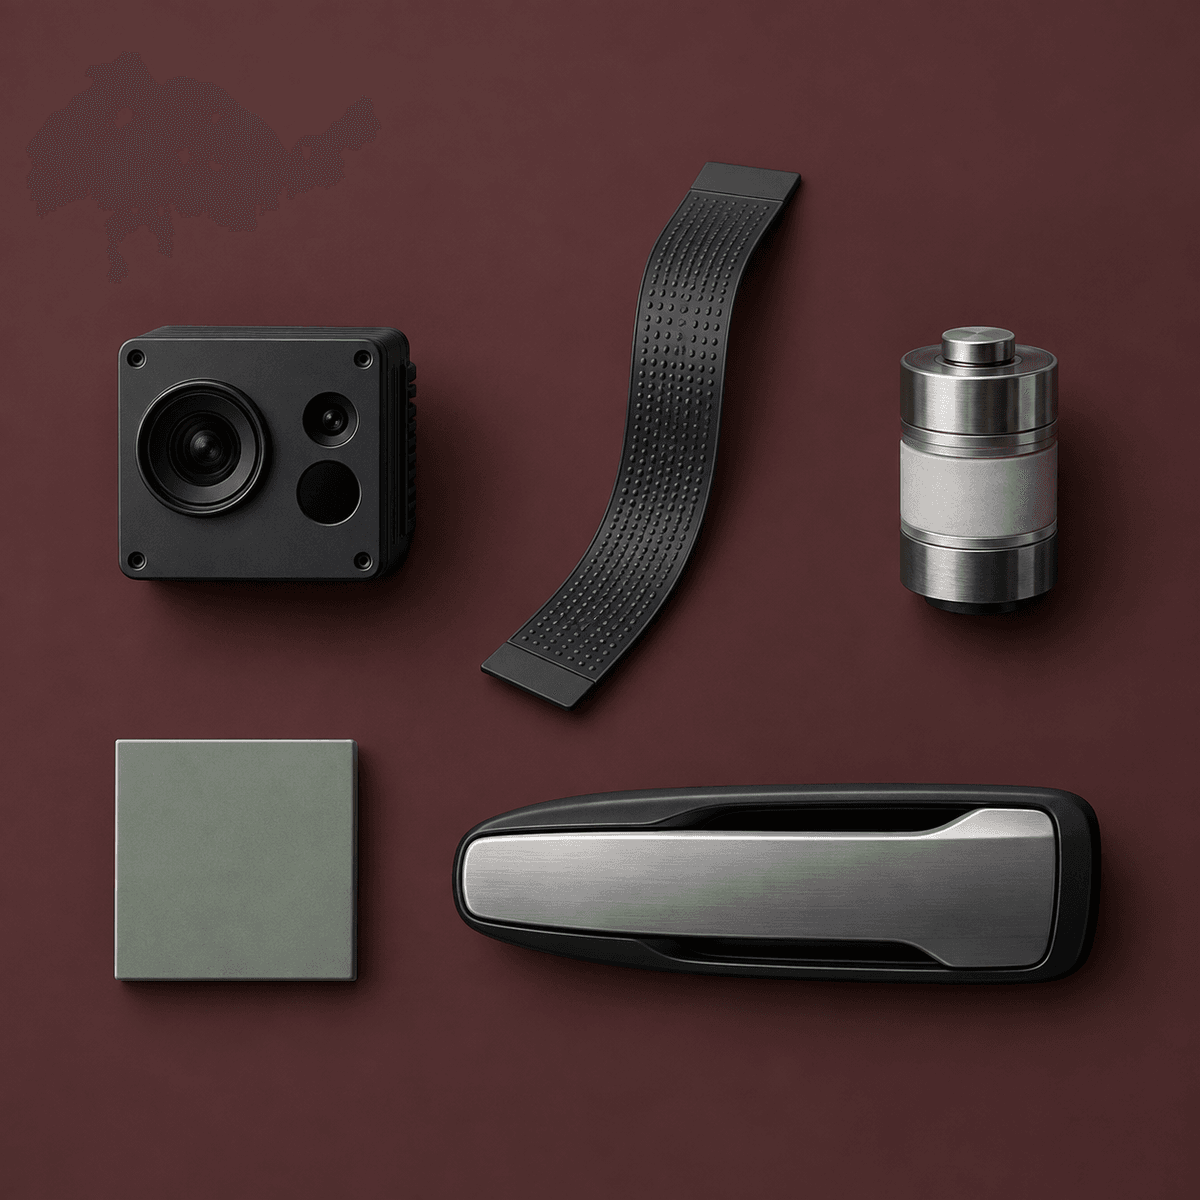
A system becomes useful when the state it senses can be traced to a proportionate, understandable response.